Master Geomatics Drone Simulation for Professional Surveying Workflows
2026-11-16
When geomatics training meets the sky, the margin for error practically vanishes before boots ever touch the ground. As surveying and mapping workflows grow more demanding, the gap between classroom theory and real-world execution has never been wider — unless you bring a true-to-life drone simulation into the equation. That’s exactly where the master-level approach to geomatics education is heading, blending professional surveying techniques with high-fidelity virtual flight. At the center of this shift sits SRIZFLY, a platform that doesn’t just mimic drone behavior — it recreates the pressure, precision, and decision-making rhythm of actual surveying missions. Whether you’re perfecting a corridor mapping sequence or practising an emergency return-to-home under variable wind loads, this isn’t gamified learning — it’s deliberate rehearsal for the field. In this post, we’ll unpack how sensor-accurate simulation reshapes everything from data capture habits to final deliverable confidence.
Simulated Flights That Mirror Real-World Survey Conditions
Simulated Flights That Mirror Real-World Survey ConditionsLiDAR and Photogrammetry Sensor Emulation Without Leaving the Office
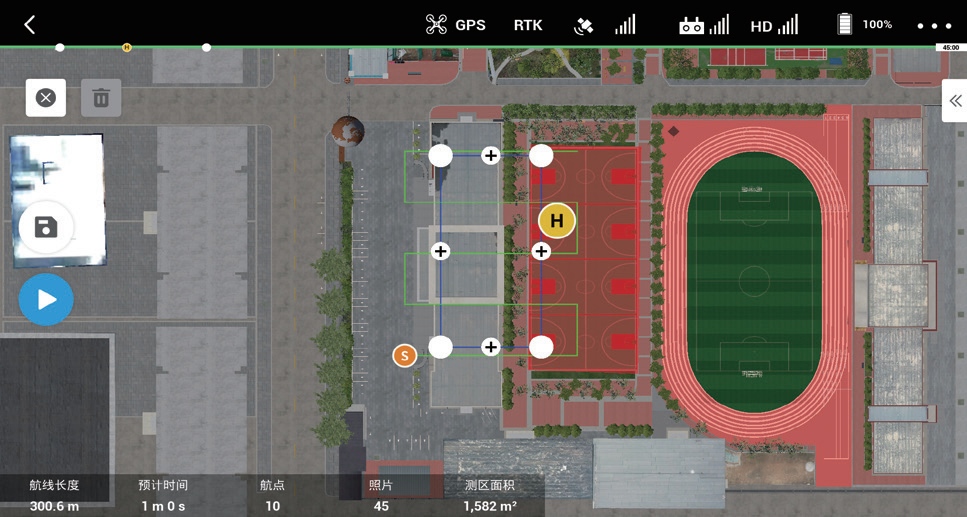
In the early days of autonomous system development, testing perception stacks meant booking a test track, waiting for the right weather, and burning through thousands of dollars in fuel just to capture a handful of edge-case scenarios. That grind has been replaced by emulation environments that synthesize raw LiDAR point clouds and photogrammetric imagery directly from virtual worlds, matching the noise profiles, reflectance quirks, and lens distortions of real sensors. Engineers can now inject dense fog, retroreflective materials, or erratic pedestrian movements at the click of a button, something that would be impossibly dangerous or expensive to orchestrate with physical hardware every single time.
What makes this approach truly powerful isn't just the safety or cost savings, but the deterministic repeatability it unlocks. When a perception module misclassifies a partially occluded cyclist at a specific intersection, the exact same scenario with the exact same sensor noise pattern can be replayed endlessly until the root cause is found. The emulator doesn't just replay recorded data, it regenerates the raw sensor feeds from scratch on each loop, allowing developers to tweak materials, lighting angles, or even the scanning pattern of a custom LiDAR design without ever touching a real device.
Bridging the gap between synthetic and real-world data remains the central challenge, and modern approaches lean on domain adaptation techniques that learn the subtle corruptions of each sensor model from a handful of calibration captures. The emulation engine then applies those learned artifacts to the pristine virtual output, producing data that aligns so closely with real returns that models trained purely in simulation can transfer to field deployments with minimal retraining. This closed-loop testing capability, from sensor physics to perception output, lets teams ship more robust systems faster while keeping the physical fleet focused on long-tail validation rather than repetitive regression runs.
Pre-Flight Workflow Testing to Eliminate Field Surprises
Nothing rattles a team more than arriving on site only to discover a workflow that looked flawless on paper crumbles under real conditions. Pre-flight workflow testing is the habit of running every step, connection, and handoff through a controlled dry run before anyone sets foot in the field. It’s about catching those small mismatches—like a tool version that silently drifts out of compatibility or a data dependency that times out when scaled—that documentation alone will never reveal. When you treat the workflow like a dress rehearsal, you surface the friction points early enough to smooth them out with calm adjustments rather than frantic workarounds.
This kind of testing thrives on a mindset shift: stop assuming you’ll iron out details on the fly. Instead, build a sandbox that mirrors field constraints—limited connectivity, varied hardware, real user roles—and walk through the exact sequence your team will follow. Pay special attention to the seams where one person’s output becomes another’s input, because those handoffs are exactly where silent errors breed. Let the process log everything, and invite the people who will actually execute the work to poke holes in it. Their “what if” questions often expose blind spots that software simulators miss.
The payoff isn’t just fewer panicked calls from the field. When a workflow passes a rigorous pre-flight test, teams arrive with genuine confidence. They’ve already seen the quirks and know the recovery steps. Over time, you build a library of these rehearsals that becomes a living playbook—one that evolves with every lesson learned, so each new project starts from a higher baseline. Field surprises never disappear entirely, but you stop being at their mercy and start treating them as manageable bumps rather than project-breaking crises.
Data Consistency Checks Using Virtual Mission Rehearsals
When military systems ingest, process, and fuse sensor data from multiple platforms, even a tiny mismatch in coordinate frames or timestamp alignment can unravel an entire mission picture. A rehearsal carried out in a high-fidelity virtual environment becomes a living test harness, replaying the exact flow of messages, target tracks, and command decisions that will occur during live operations. By running these digital dress rehearsals, engineers intentionally trigger corner cases—dropped packets, late-arriving imagery, unsynchronized clocks—and watch whether the downstream common operating picture degrades gracefully or fractures without warning.
The real value surfaces not when everything works, but when the virtual mission exposes assumptions baked into integration code. For example, a track correlation algorithm might assume that all contributors report in Earth-centered Earth-fixed coordinates, yet one legacy sensor outputs in a local tangent plane with vague georeferencing. The virtual rehearsal replays that exact data stream and immediately reveals the geographic shift that operators would otherwise dismiss as a sensor bias. These controlled injections turn data consistency from a paper checklist into an observable, debuggable behavior that leaves a forensic trail in the logs—exactly what analysis teams need long before hardware reaches the field.
Teams who adopt virtual mission rehearsals as a consistency checkpoint soon find that the boundary between integration testing and operational readiness blurs. They stop asking “does the interface comply with the specification?” and start asking “will the commander trust the screen when it matters?” That subtle reframing makes all the difference, because a perfectly formatted message that carries misaligned coordinates is just noise dressed as signal. The virtual rehearsal becomes a shared language between developers, testers, and warfighters—a place where data fidelity is judged not by schemas but by the outcome of a simulated engagement.
Translating Simulation Insights into On-Site Efficiency
Bridging the gap between virtual models and physical worksites demands more than just accurate data—it hinges on interpreting what the numbers mean for boots-on-the-ground decisions. When a simulation flags a bottleneck at the loading dock, the real value lies in mapping that insight to crew shifts and equipment staging before the delay ever materializes. It’s about treating each simulation output as a narrative of potential friction points, not a final verdict.
Too often, detailed reports are handed off without context, leaving field teams to sift through charts that were never designed for their daily rhythms. Turning analysis into action means stripping away the layers of abstraction: replacing “throughput variance” with “two extra pallets an hour if we rearrange the conveyor’s feed angle.” This translation process becomes a shared language where planners and operators co-own the efficiency gains, making the leap from model to motion almost muscle memory.
Sustaining that momentum requires a feedback loop that works in both directions. When on-site observations—like a supervisor noticing a recurring micro-stop that the simulation missed—are fed back into the digital twin, the model evolves from a one-time snapshot into a living benchmark. The facilities that pull ahead are those that refuse to treat simulation as a ceremony reserved for the design phase, embedding it instead as a tool for daily course correction and continuous fine-tuning of workflows.
Error-Proofing Survey Projects Through Digital Dry Runs
The idea of a dry run isn’t new, but applying it digitally to survey fieldwork changes how we catch mistakes before they happen. Instead of hoping the questionnaire logic holds up in the field, teams now simulate the entire data collection flow in a controlled virtual environment. This means running test interviews with dummy respondent profiles, forcing edge cases like skip patterns triggered by unexpected answers, and watching how the system behaves when connectivity drops mid-survey. The goal is to break the instrument early and quietly, away from real respondents, so every glitch becomes a learning point rather than a field failure.
What sets digital dry runs apart is the layer of realism they can incorporate. You’re not just clicking through a survey preview; you’re mimicking genuine field conditions, including device types, screen sizes, and even low-bandwidth scenarios that often trip up mobile data collection. Error-proofing here means paying attention to the non-obvious: how a date picker renders on an older tablet, whether a progress bar misleads interviewers into skipping sections, or if a required photo question blocks submission because the file size limit was never clearly communicated. These rehearsals surface friction points that a standard logic check would never flag.
Beyond technical validation, digital dry runs build a shared understanding among the project team. When field supervisors, data managers, and questionnaire designers sit together—even virtually—and walk through the simulated survey, they start spotting misinterpretations that a written script hides. A question that seemed clear in English might fall apart when pushed through a translation interface; an interviewer instruction note might get buried in a cluttered screen layout. Running these collaborative simulations turns individual assumptions into collective fixes, so that by the time the first real interview starts, the tool isn’t just functional, it’s practically hardened by the very people who will use it.
FAQ
It lets professionals test flight plans and sensor configurations under real-world variables without risking expensive hardware or wasting field time. The virtual environment mimics terrain, weather, and GPS conditions closely enough to expose workflow flaws before you ever leave the office.
Instead of just reading about oblique imagery or LiDAR flight patterns, you manipulate a virtual drone through topographic challenges, adjust overlaps on the fly, and see the immediate impact on data coverage. This hands-on repetition builds instincts no slide deck can teach.
Yes, you switch between nadir cameras, oblique sensors, and LiDAR units within the same simulated project. Each payload changes the flight dynamics and collection logic, so you learn to adapt mission parameters for photogrammetry versus laser scanning without touching a single piece of real gear.
Things like emergency corridor mapping after a simulated flood, volumetric calculations over a virtual quarry with steep faces, or flights in gusting crosswinds that would ground a real crew. You can deliberately push into marginal conditions to understand where your data quality actually breaks down.
Seasoned surveyors use it to validate complex multi-battery LiDAR missions for large infrastructure sites or to experiment with terrain-following algorithms before a critical data capture. It's as much a risk-management tool for specialists as it is a training ramp for newcomers.
You can generate a preview point cloud or orthomosaic from the simulation, letting stakeholders see exactly what coverage and resolution to expect. This turns the pre-survey meeting into a much more concrete conversation about outcomes rather than abstract flight plans.
The in-field setup and trial flights often eat up half a day on a complicated site. By nailing the flight parameters and sensor settings ahead of time, many teams report cutting on-site drone time by a third or more, which directly reduces weather delays and crew costs.
Conclusion
Pushing geomatics drone operations beyond guesswork demands a simulation environment that faithfully replicates the complexities real pilots face. Instead of treating flight software as a simple waypoint planner, the approach immerses operators in sessions where wind gusts, signal degradation, and terrain occlusions disrupt a mission just as they would on site. Laser scanner and camera payloads are virtualized with enough fidelity to produce point clouds and orthoimages that reveal sensor noise, shadow patterns, and multipath errors long before a battery is charged. This means the team can pressure‑test full acquisition workflows, adjusting overlap settings or gimbal pitch while watching how data quality evolves under harsh but predictable digital weather. The end result is a rehearsal that strips away false confidence, leaving only procedures that have already proven themselves against the same obstacles that routinely delay field crews.
What matters most is how those virtual repetitions translate into muscle memory and risk removal when the drone actually takes off. By running the exact mission file through the same ground control app used outdoors, surveyors catch coordinate system mismatches, airspace conflicts, and battery‑margin illusions while they are cheap to fix. Repeated dry runs also generate benchmark datasets that become a golden reference for later reality‑checking: if live lidar strips start drifting, the team quickly compares the pattern against the simulated baseline to separate sensor failure from operator error. Over successive projects, this loop builds a library of failure modes and fixes, turning each digital rehearsal into a permanent asset rather than a one‑off box‑tick. The payoff shows up as shorter time on the ground, fewer return visits, and deliverables that pass accuracy audits without relying on post‑processing heroics. Ultimately, the simulation becomes the surveyor’s quiet co‑pilot, making every real sortie feel like familiar territory.
Contact Us
Contact Person: Niles Liu
Email: [email protected]
Tel/WhatsApp: 8619945009803
Website: https://srizfly.com/